A graphite-black autonomous electric sedan driving along a coastal highway at dusk

F Saeflower · Autonomous Driving

See every meter.
Reach every destination.

We build fully autonomous driving systems around multi-sensor fusion perception, bringing safety, composure and predictability to real roads.

Explore the technologyarrow_downwardContact us

Our philosophy

Autonomy is not assistance. It is a driver that is always present, never tired and never distracted.

360°
Blind-spot-free perception in every direction
24/7
Designed for round-the-clock, all-weather operation
2×
Primary and backup systems for compute, braking and steering

Vehicle

A platform built for perception.

Every sensor position and every redundant path is considered from the first day of vehicle design, not bolted on afterward.

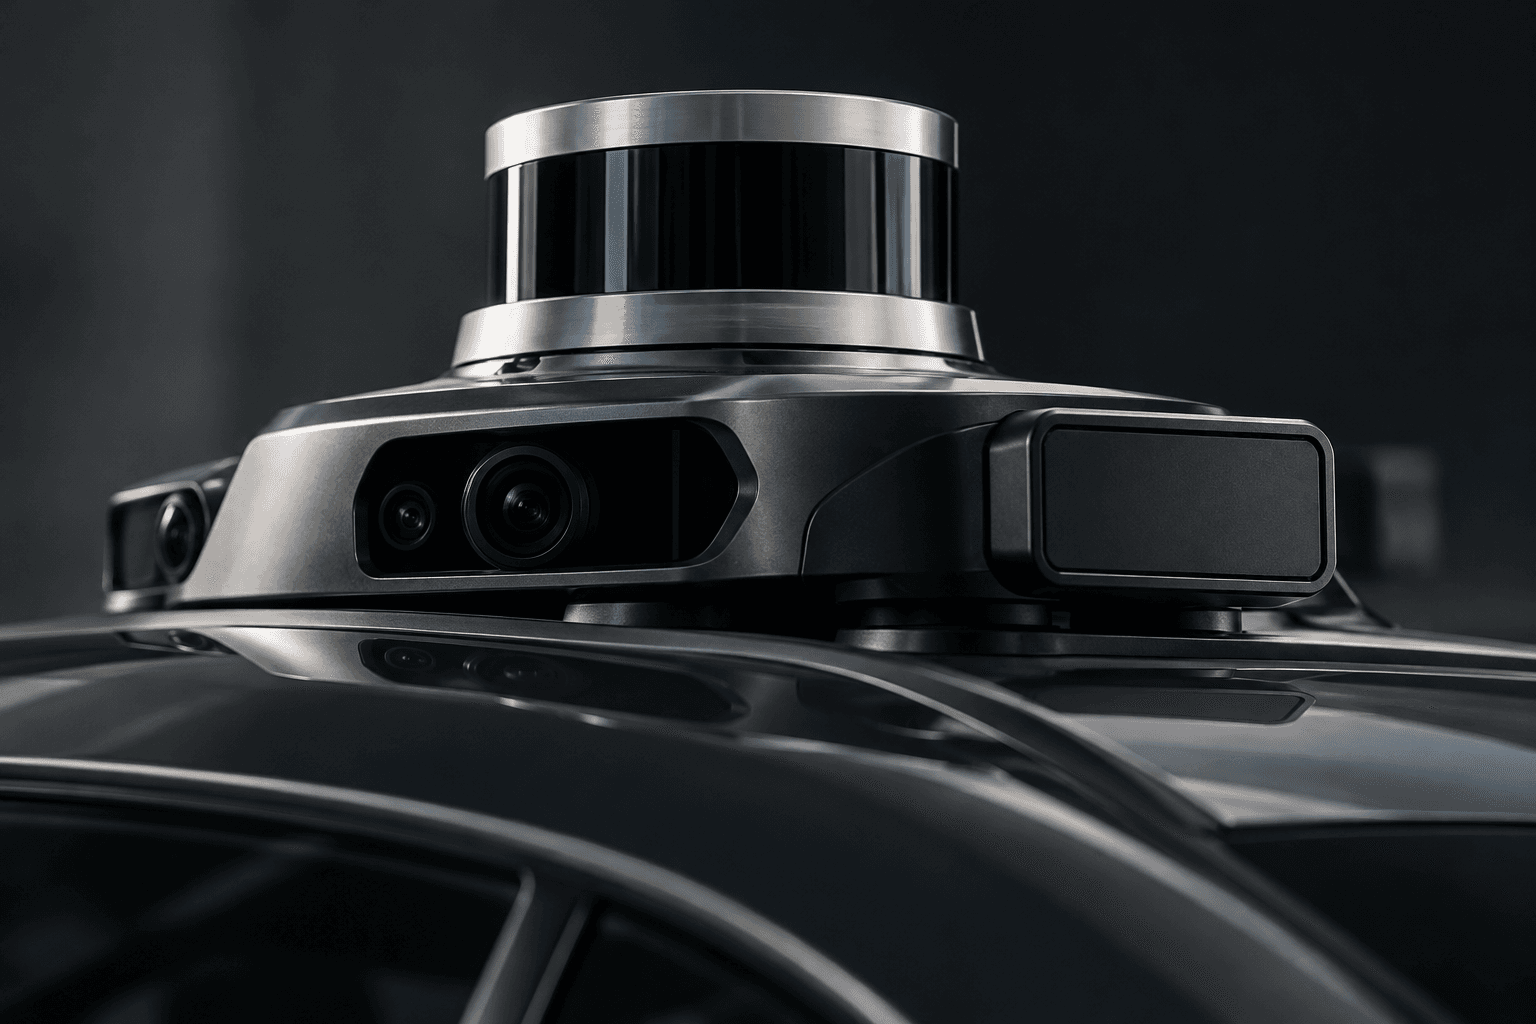
Close-up of the roof-integrated sensor module with lidar, cameras and radar
  • Sensor suite

    Lidar, surround cameras and millimeter-wave radar work together for full 360° coverage.

  • Compute platform

    Automotive-grade heterogeneous compute with primary and backup systems running in parallel for real-time perception, prediction and planning.

  • Drive-by-wire chassis

    Redundant steering and braking channels respond precisely and quickly to every decision.

  • Electric powertrain

    A quiet, smooth electric platform built for scalable, all-weather operation.

  • Passenger space

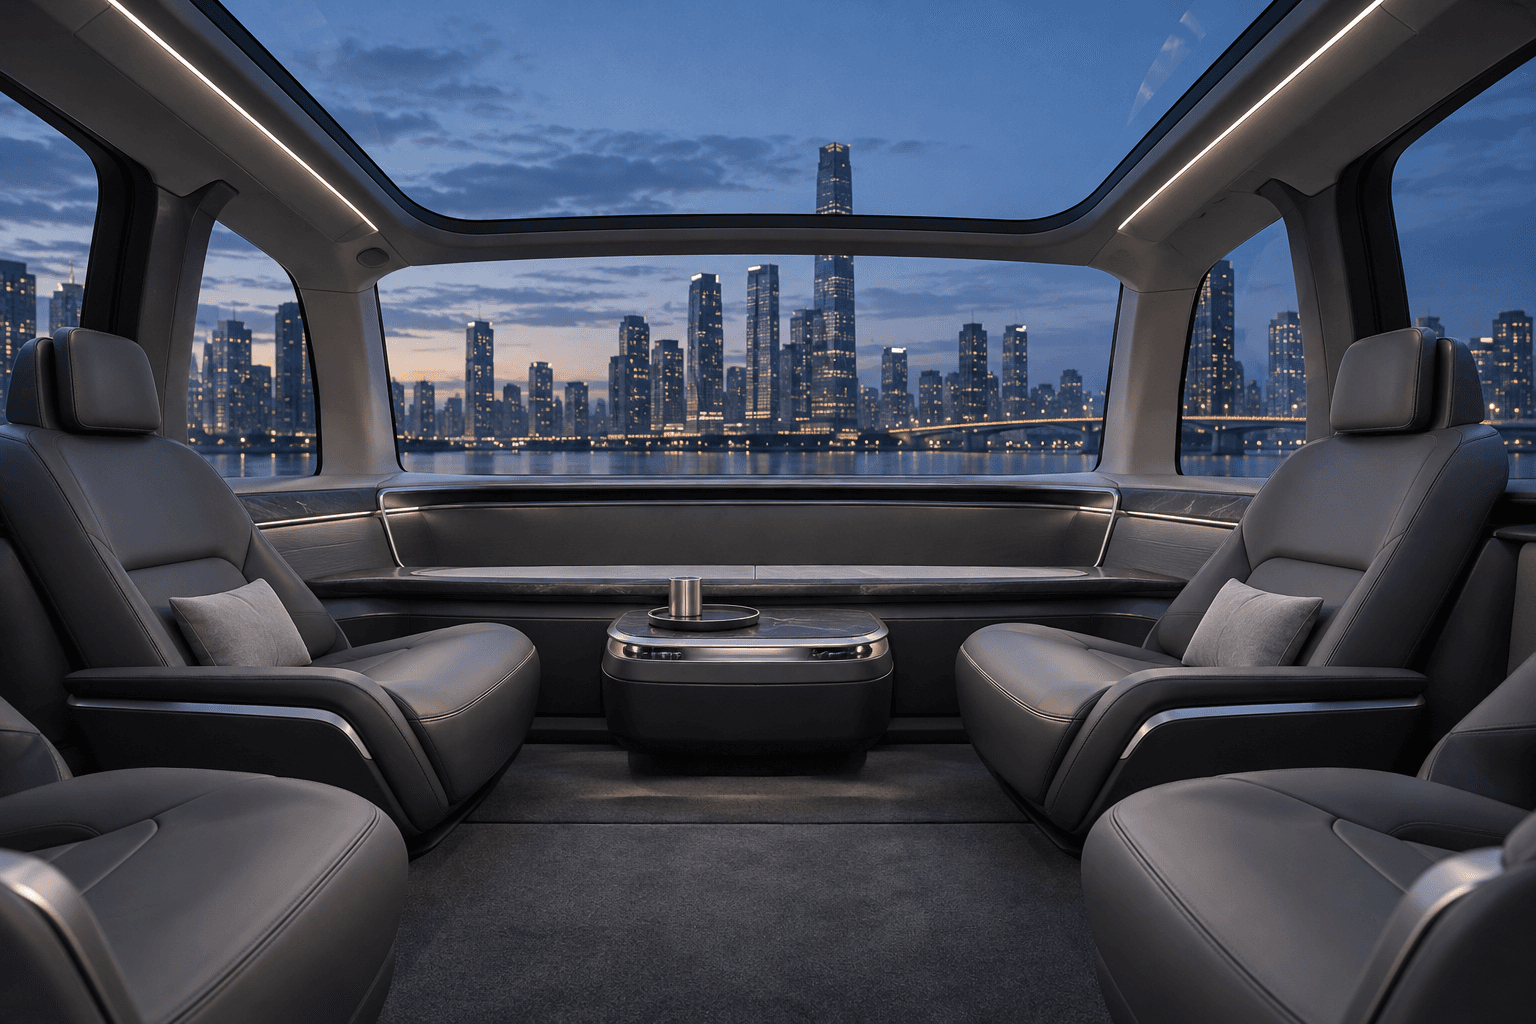
    A cabin designed for riding, not driving. No manual intervention, just a calm journey to the destination.

Perception

From seeing,
to understanding, to deciding.

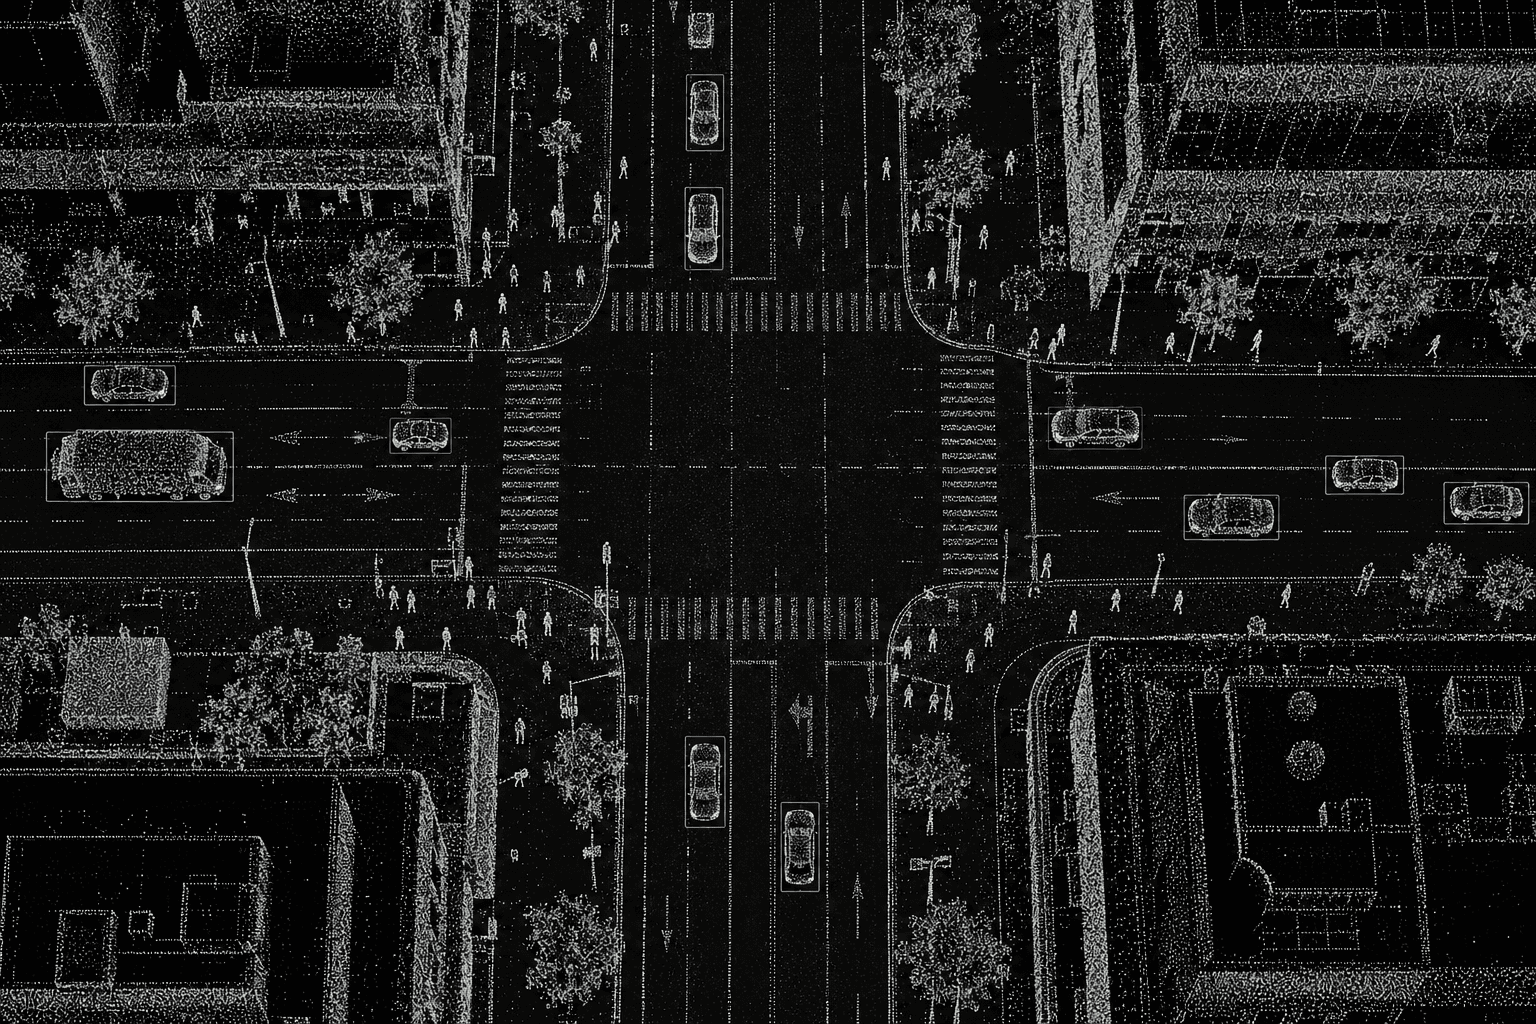
The system continuously rebuilds the three-dimensional world around the vehicle, then localizes, predicts and plans within it.

Lidar point cloud view of a city intersection with vehicles and pedestrians outlined
  1. 01 · Localize

    Always know where it is.

    High-definition maps, inertial navigation and live perception cross-check each other, holding a stable, continuous position through tunnels, urban canyons and overpasses.

  2. 02 · Perceive

    See everything at once.

    Lidar, camera and radar data are fused into a single coordinate frame to identify pedestrians, cyclists, vehicles, work zones and traffic signals.

  3. 03 · Predict

    Understand before it happens.

    The system models the intent of every road user, simulates multiple possible trajectories and evaluates how each one affects the vehicle’s path.

  4. 04 · Plan

    Choose the steadiest path.

    It solves for the best trajectory between safety, compliance and comfort, then outputs smooth speed, lane and steering decisions.

Sensor suite

Different principles, cross-checking each other.

LidarCamerasRadarCompute

Light as a ruler for three-dimensional space.

Laser pulses are emitted in every direction and timed on return, producing a precise 3D point cloud around the vehicle. It needs no ambient light, so performance is the same day and night.

  • checkLong-range detection paired with near-field coverage
  • checkAccurate shape and position of every object

Applications

Real roads,
real needs.

One driving capability, serving different mobility and transportation needs across cities, highways and campuses.

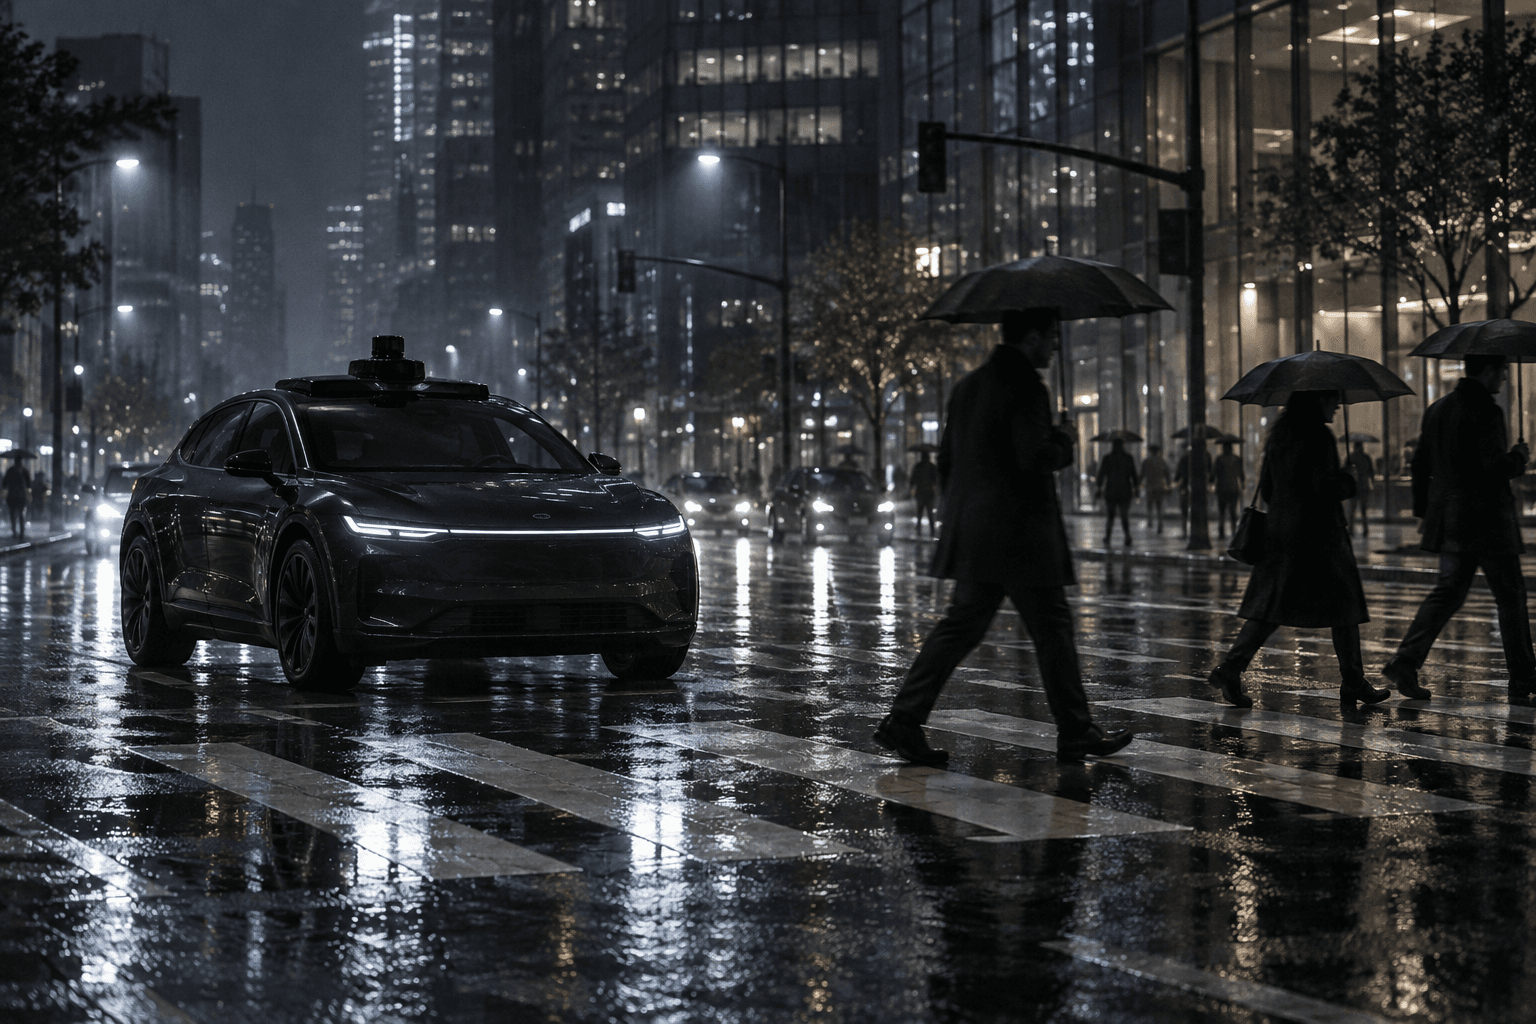
An autonomous robotaxi stopping calmly at a crosswalk on a rainy city street at night

01 · Urban mobility

Composed on the most complex streets.

Dense pedestrians, cyclists and intersection negotiation are the true test of urban autonomy. The system drives smoothly and predictably, for a ride that feels safe.

  • Intersection handling
  • Pedestrian and cyclist yielding
  • Night and rain operation
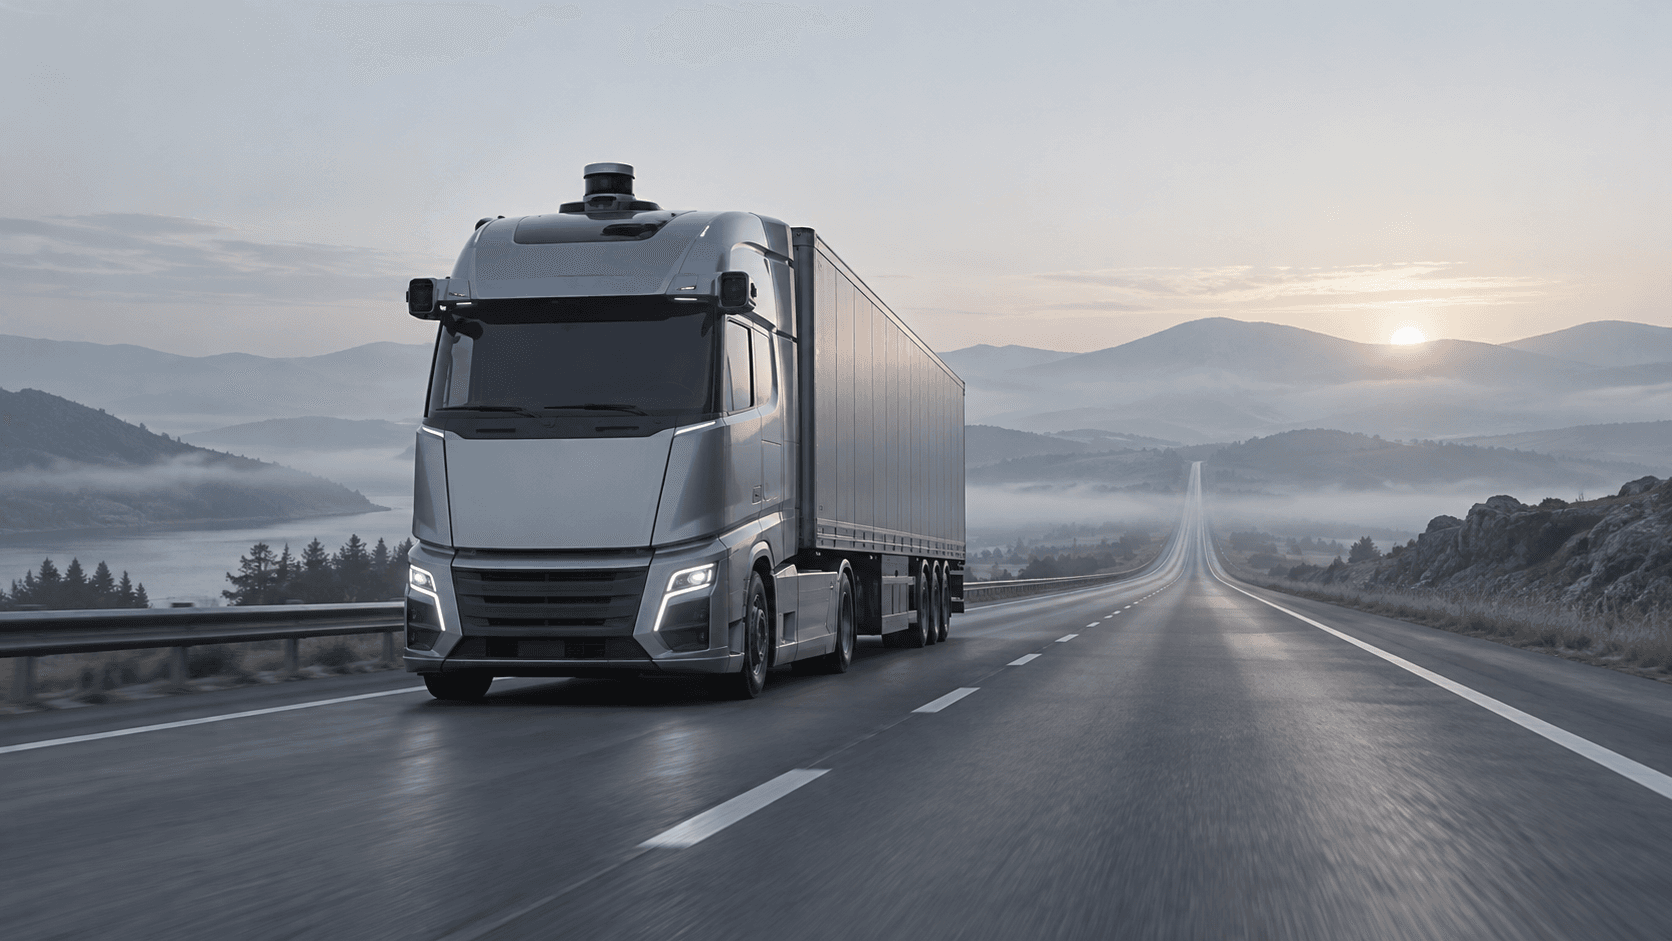
An autonomous heavy truck driving on a straight highway at dawn

02 · Freight

Steady delivery across a thousand miles.

On long highway runs the system holds following distance, lane and speed with precision, reducing fatigue risk and improving transit efficiency and on-time delivery.

  • Highway cruising
  • Long-duration operation
  • All-weather service
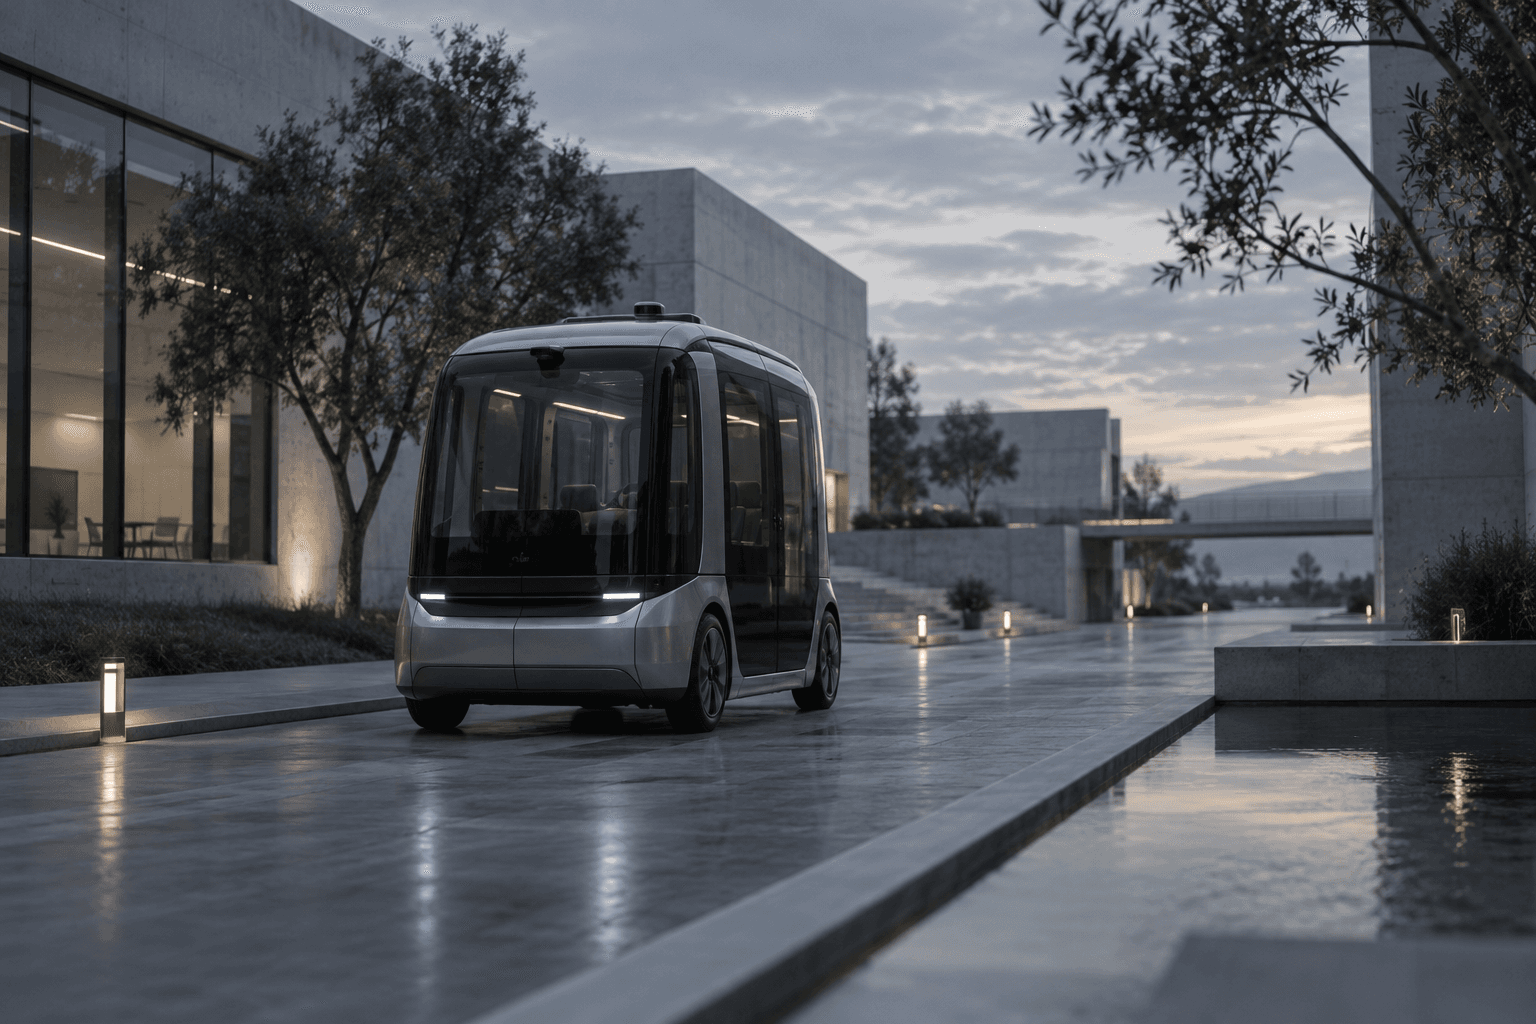
A driverless electric shuttle gliding through a modern tech campus

03 · Campus shuttle

Quiet, unhurried, on demand.

In campuses, ports, airports and communities, low-speed autonomous shuttles make short trips easier and quieter.

  • Fixed routes
  • Low-speed safety
  • Flexible dispatch

Safety

Safety is where the system starts,
not something added on.

  • Redundant compute

    Primary and backup computers run in parallel. If the primary fails, the backup takes over and performs a minimal-risk stop.

  • Redundant braking and steering

    Independent braking and steering channels mean that if one fails, the vehicle can still slow and pull over under control.

  • Independent power

    Critical driving systems have separate power circuits, removing any single point of failure.

  • Cross-validated sensing

    Sensors built on different physical principles confirm one another, reducing the risk of a single sensor’s misjudgment.

  • Network and data security

    End-to-end protection from vehicle to cloud, following security practices recognized by industry and regulators.

Three layers of validation before any road.

01

Closed course

Rare and complex scenarios are reproduced in a controlled environment, and every response is verified again and again.

02

Public roads

The system runs and is evaluated in real traffic, improving continuously in the real world.

03

Large-scale simulation

Real driving is replayed and extended, so the most challenging situations are met in a virtual world first.

A steering-wheel-free autonomous cabin with facing graphite seats and a panoramic glass roof

Partnerships and inquiries

Let's redefine
how people move.

Whether it is vehicle partnerships, operations or a technical conversation, we would like to hear from you.

frank@fsaeflower.comarrow_forward